Products ___
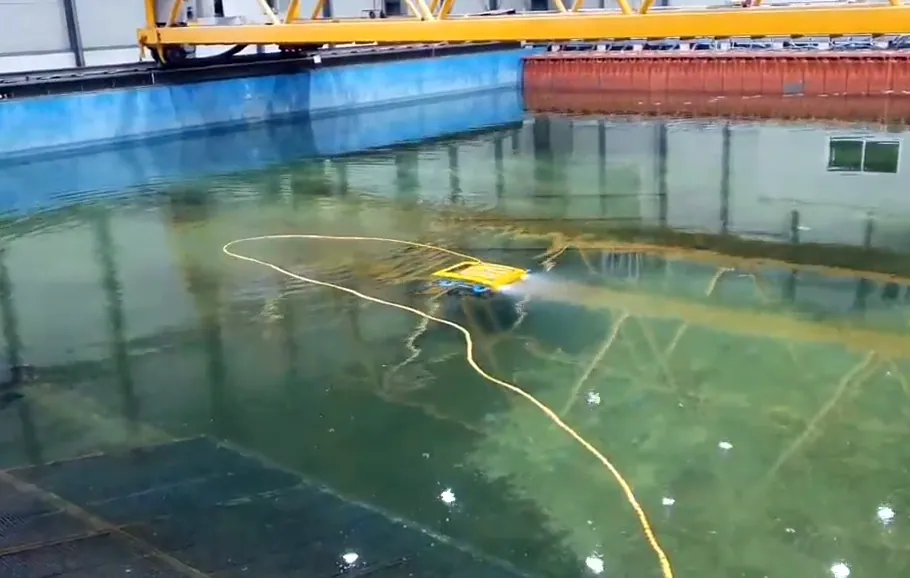
Underwater Work Robot
ROVINS V4
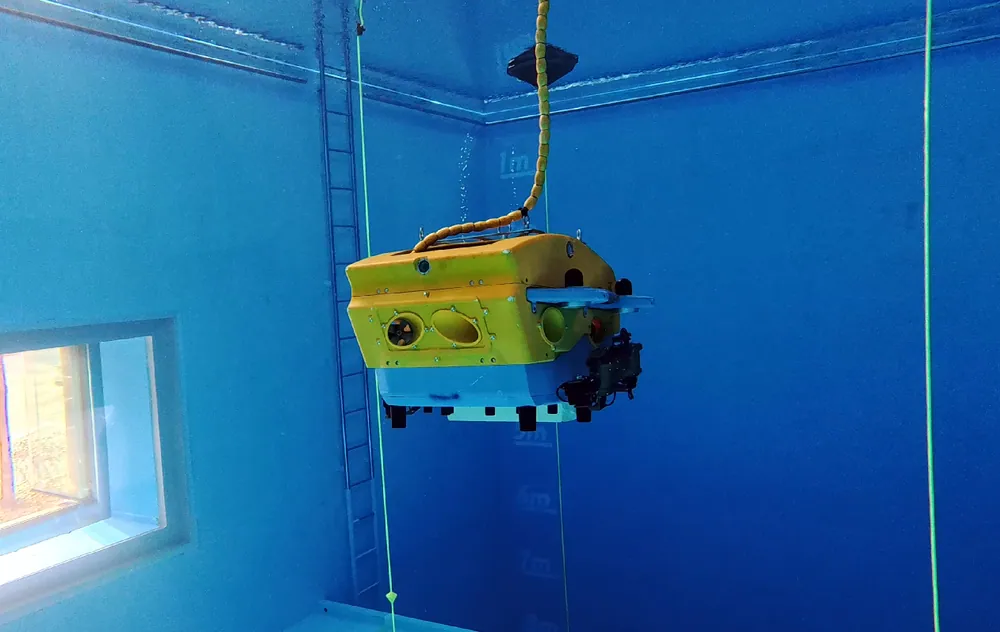
Youngpoong’s unique underwater work and inspection
Products __
Underwater Work RobotROVINS V4
Youngpoong’s unique underwater work and inspection
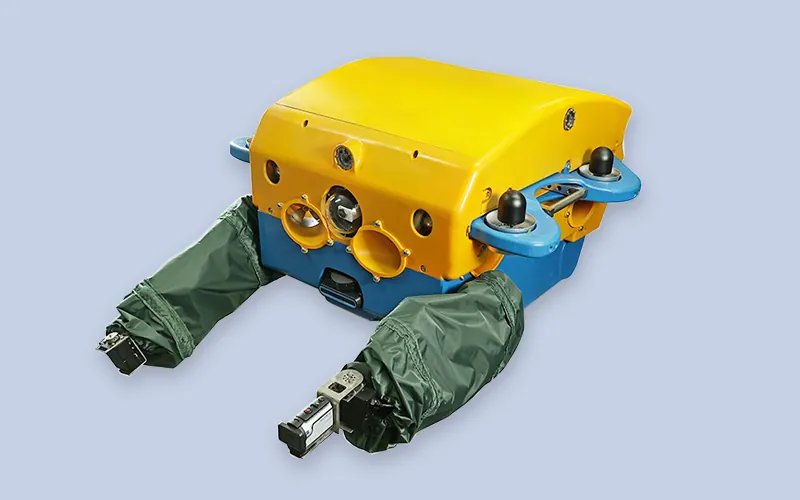
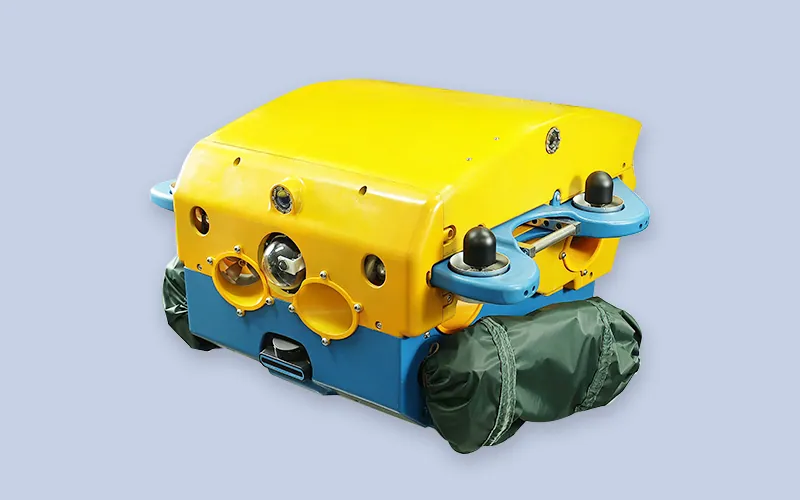
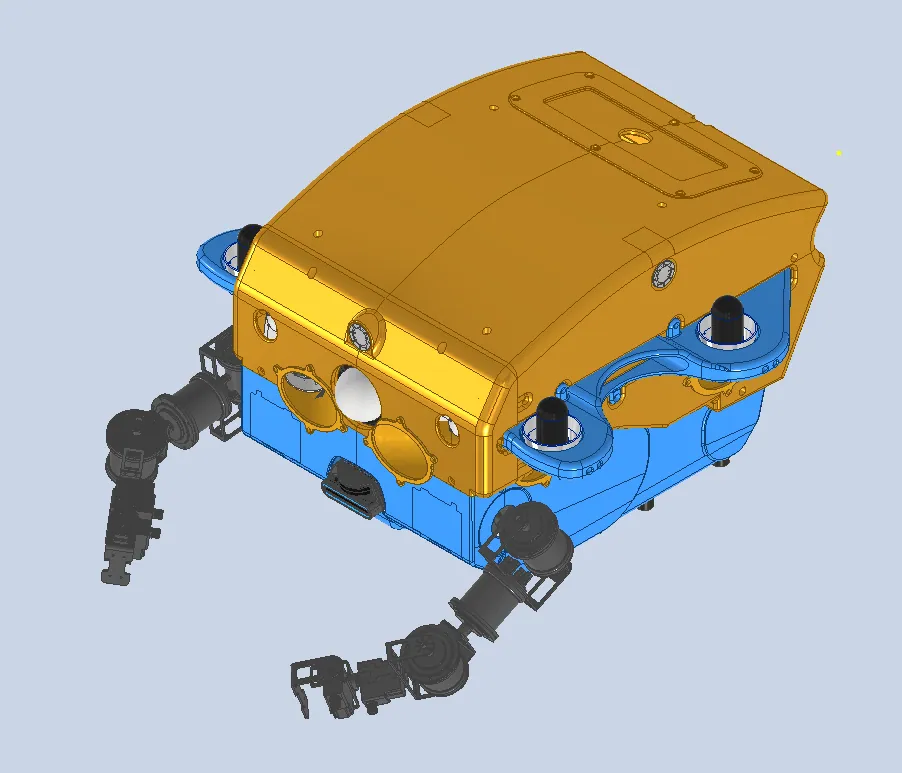
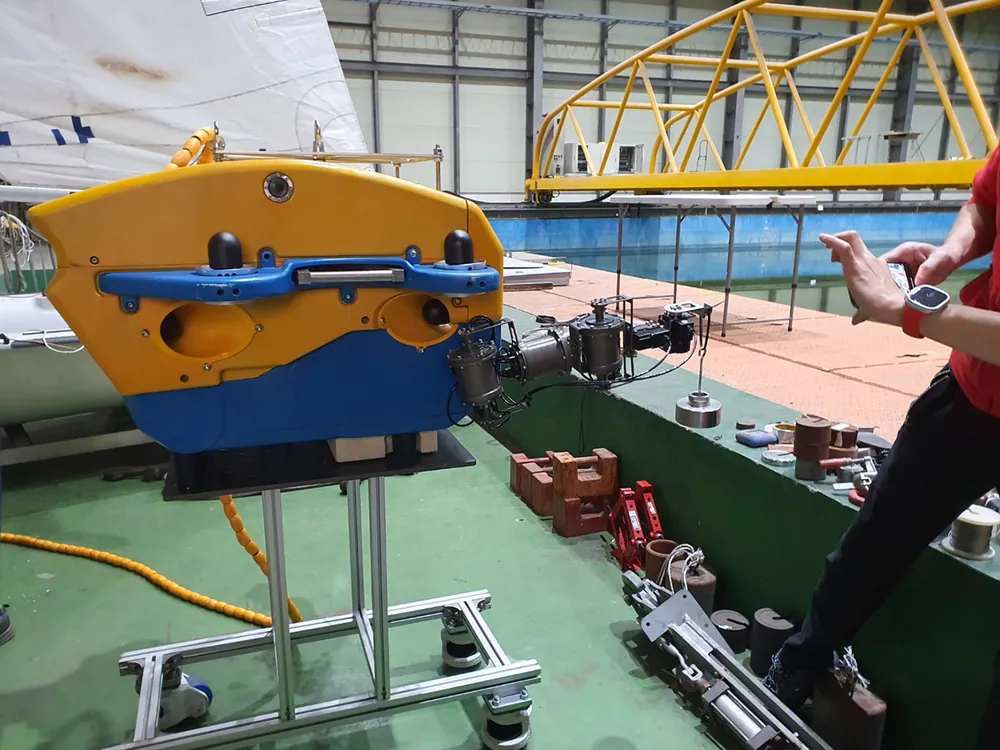
6-joint Robotic Arm for Underwater Work
ROVINS-V4
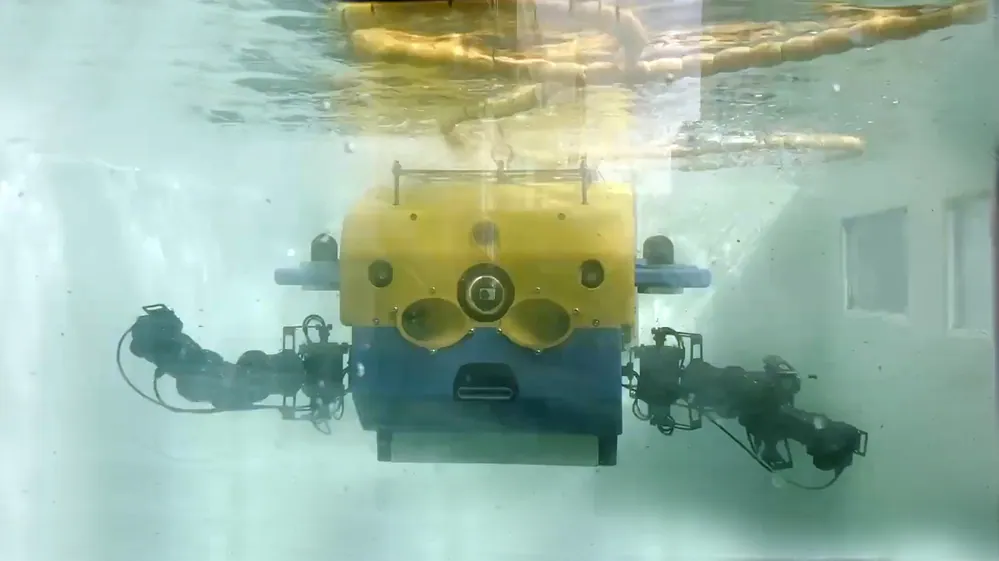
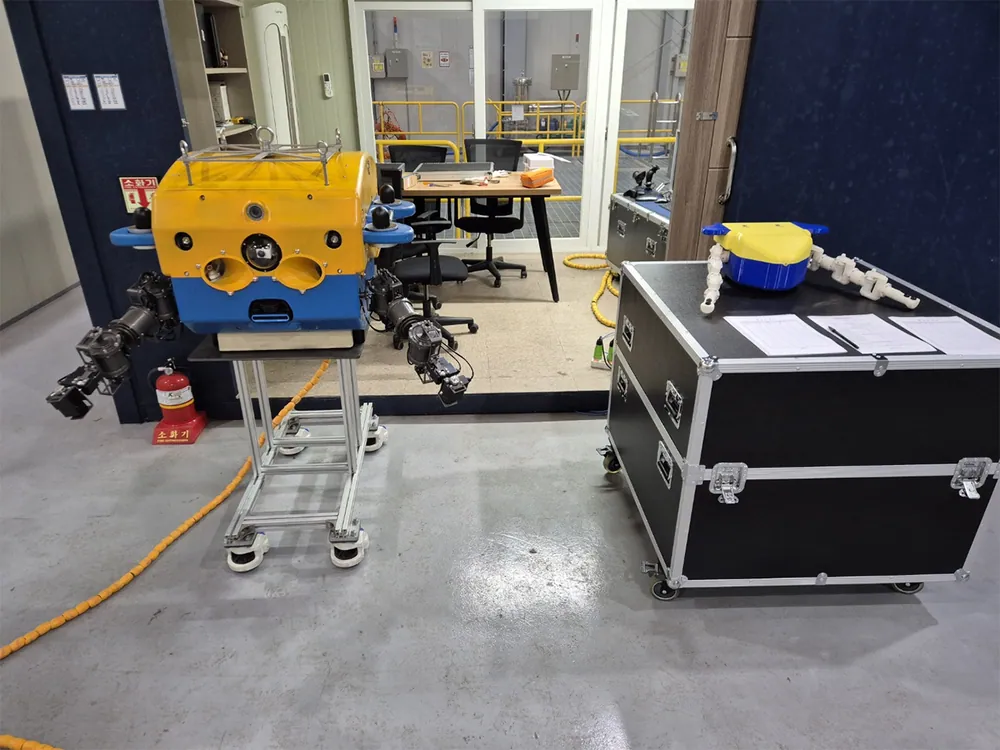
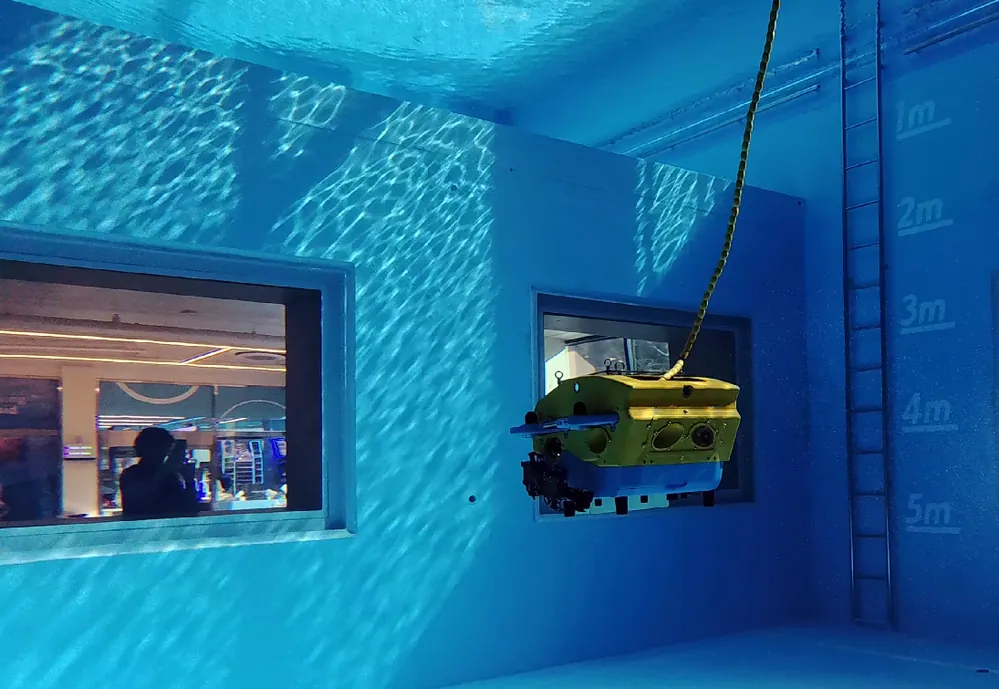
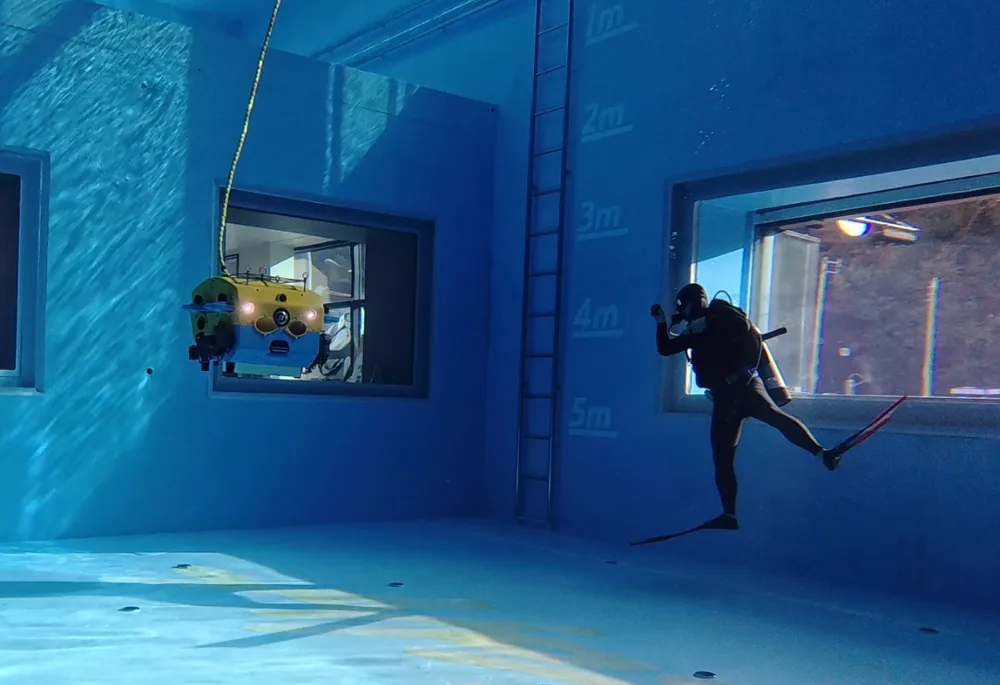
6-jointed, double-armed robot for underwater work
• 6-jointed, double-armed robot for underwater work
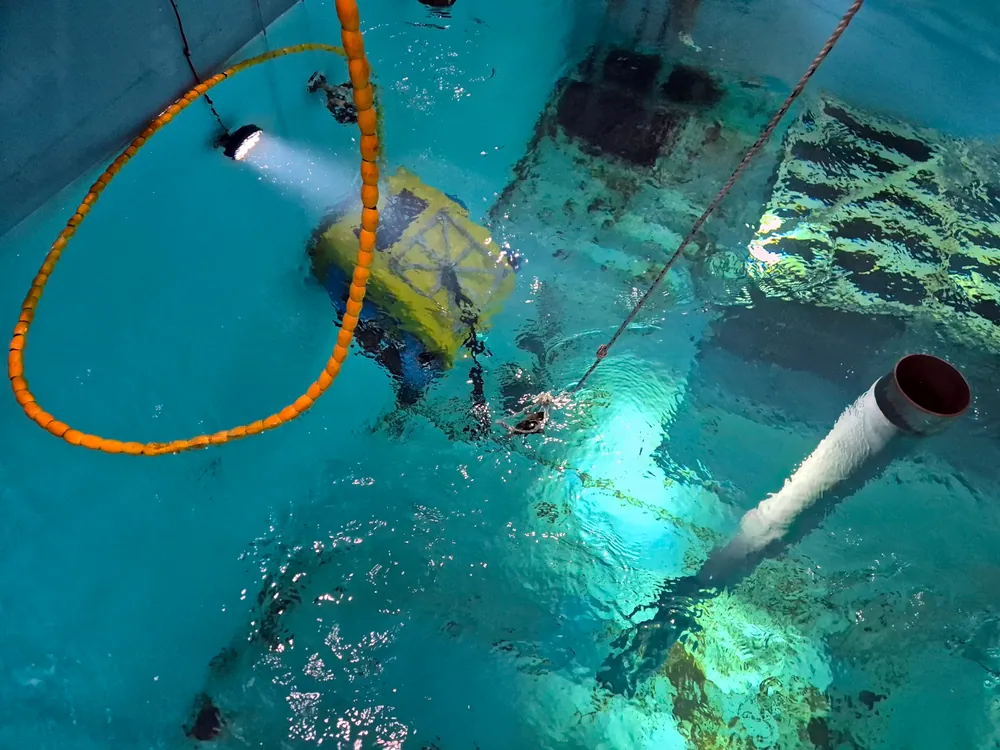
• Two-armed robot can remove debris and perform simple tasks underwater
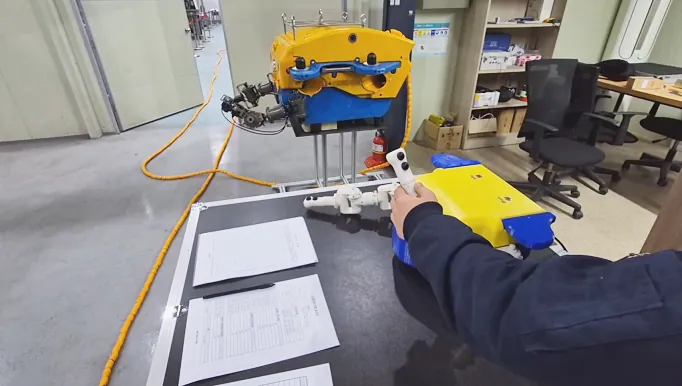
• Immersive controller for convenient operation
ROVINS = ROV(Remotely Operated Vehicle) + INSPECTION
Features
6-joint Robotic Arms
Equipped with 6-joint robotic arms resembling human arms, enabling operations similar to a diver’s underwater tasks
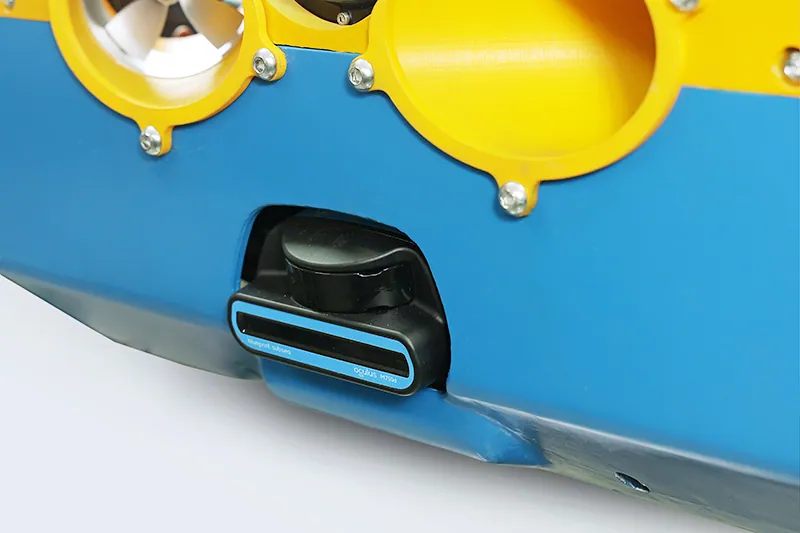
2D Sonar Sensor
2D ultrasonic precision sensor enables navigationthrough obstacles and seabed up to 40-120 meters ahead
Debris removal and light handling
Two-armed robot can remove debrisand perform simple tasks underwater
Joystick
Joystick and arm positioning synchronized in real timeEasy control through realistic flight stick
Replaceable module type
Replace brushes, cameras, grippers, etc.with interchangeable modules on the end of the robot arm
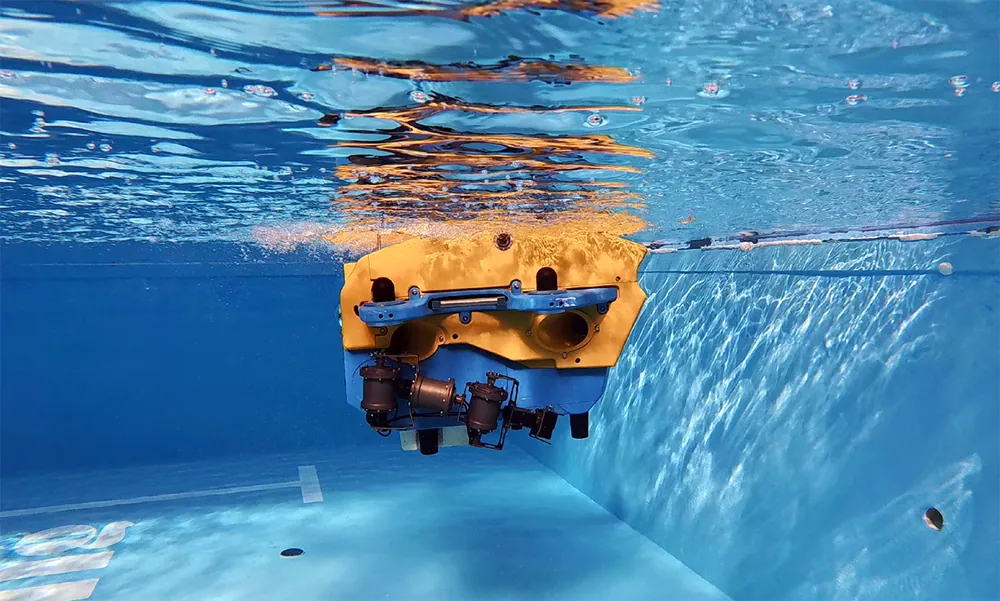
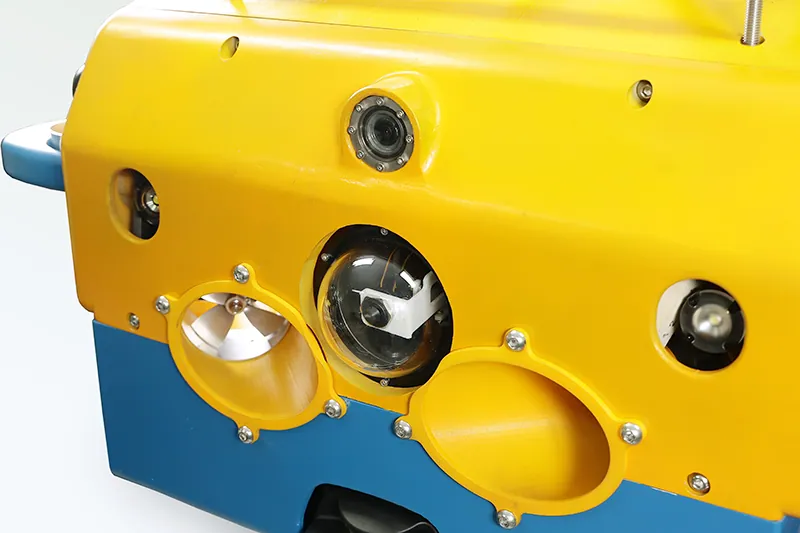
8 underwater thrusters
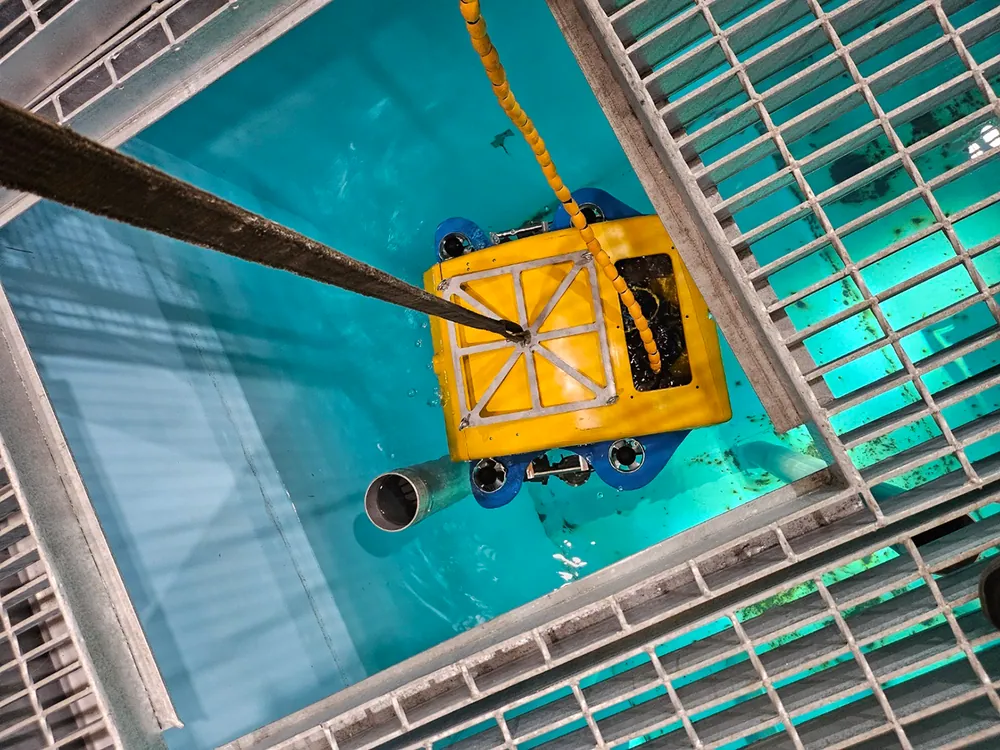
Freedom of movementwith 8 underwater thrusters
Control System
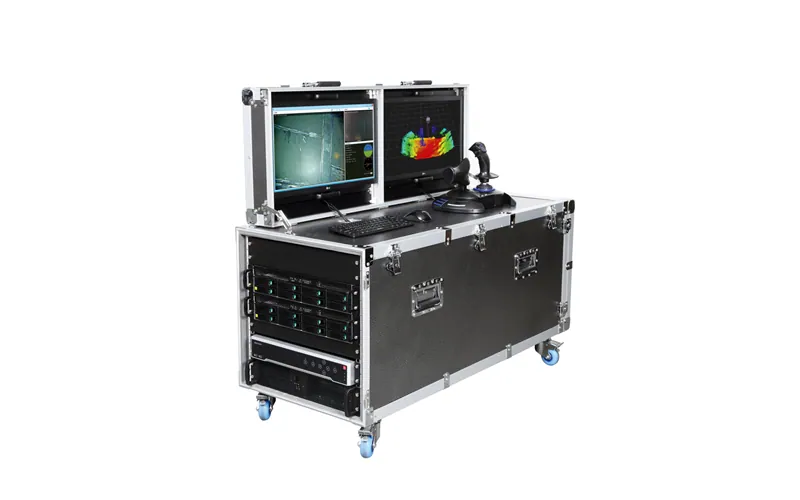
ROVINS is an operations and control system
for underwater robots.
- Equipped with dedicated control and inspection software for underwater robots
- Equipped with dual-arm control and simulation program
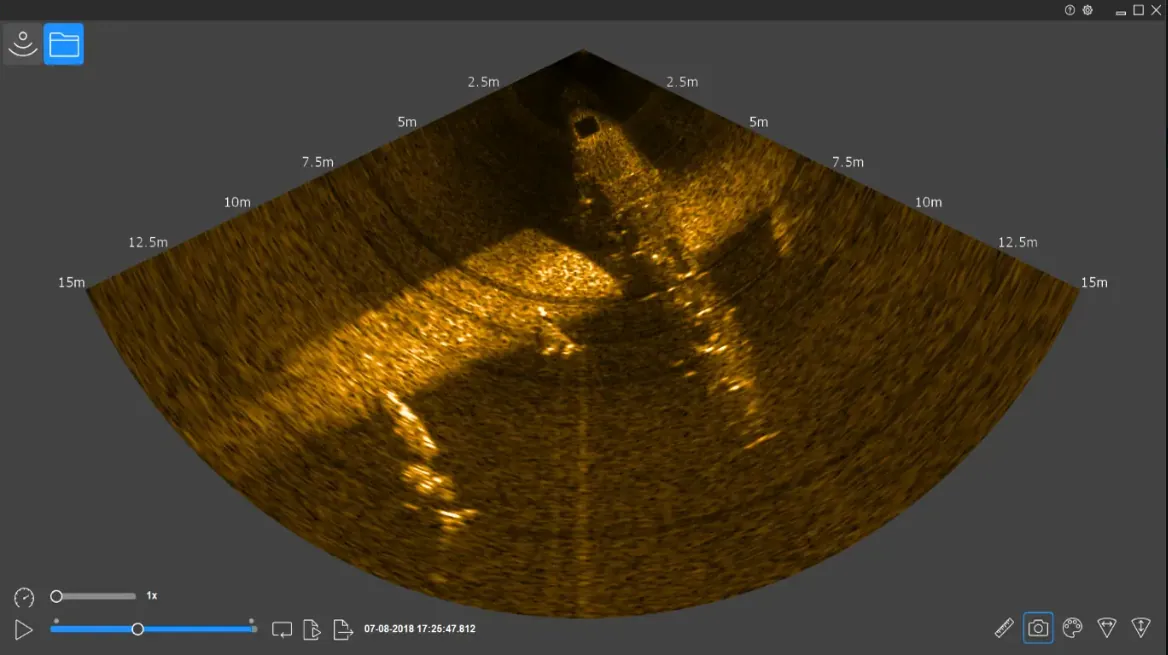
- Seafloor exploration via 2D sonar program
- Power supply module installed for continuous inspection
- NVR(Network Video Recorder)
Program Capture
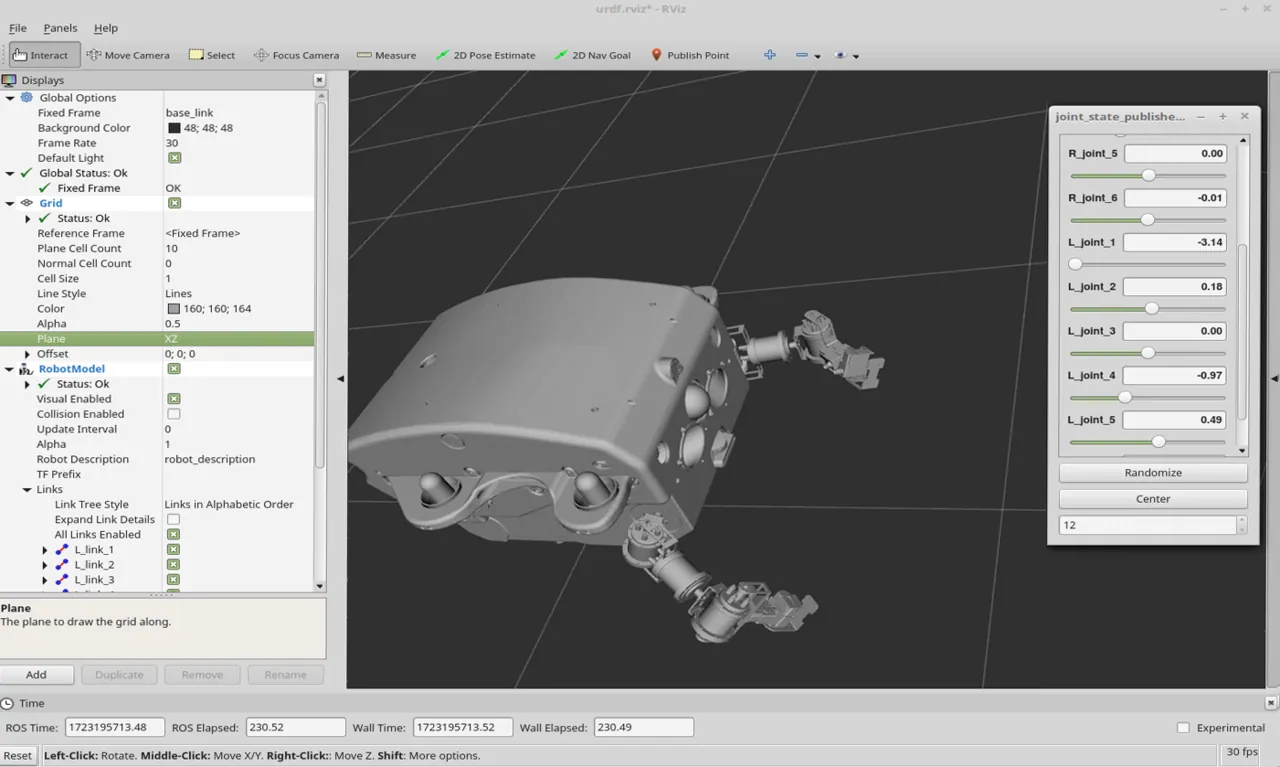
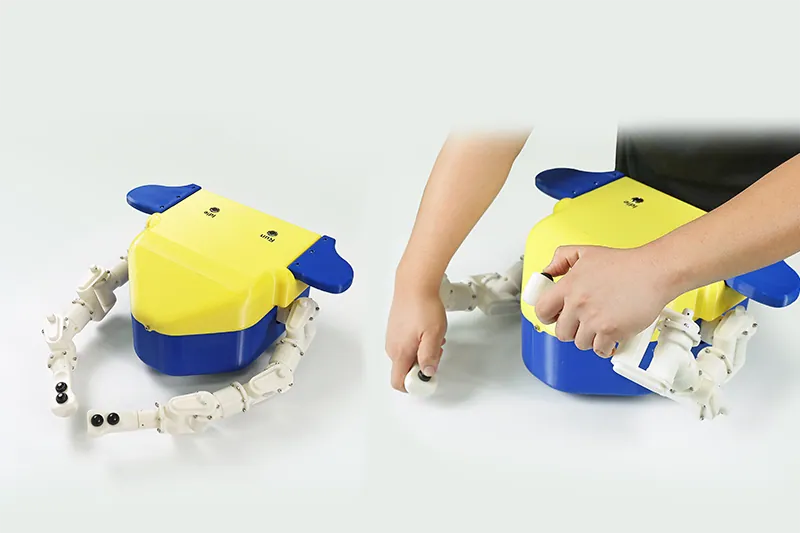
01 Immersive Controller
- Perform simple tasks underwater with a 3kg airborne load
- Perform delicate underwater tasks with articulated double-arm
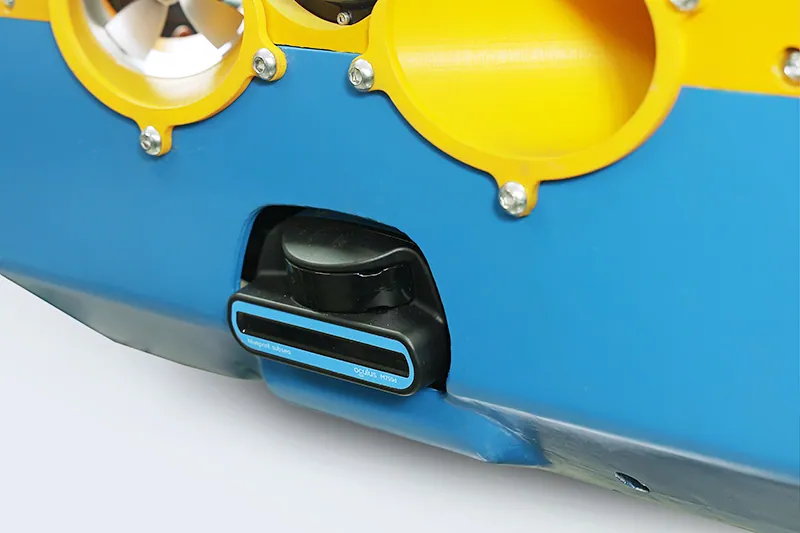
02 2D Sonar Sensors
- Frequency : 750kHz - 1.2MHz
- Max Range : 40~120m
- Field of View : 130°/ 20°
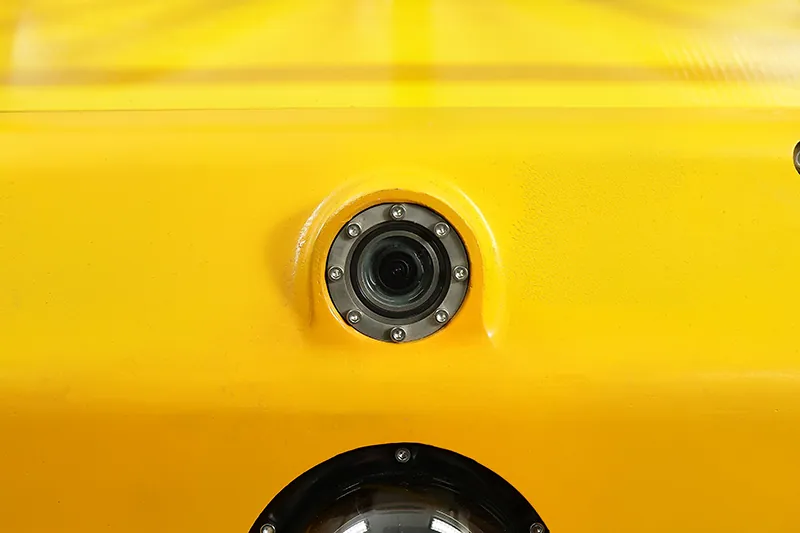
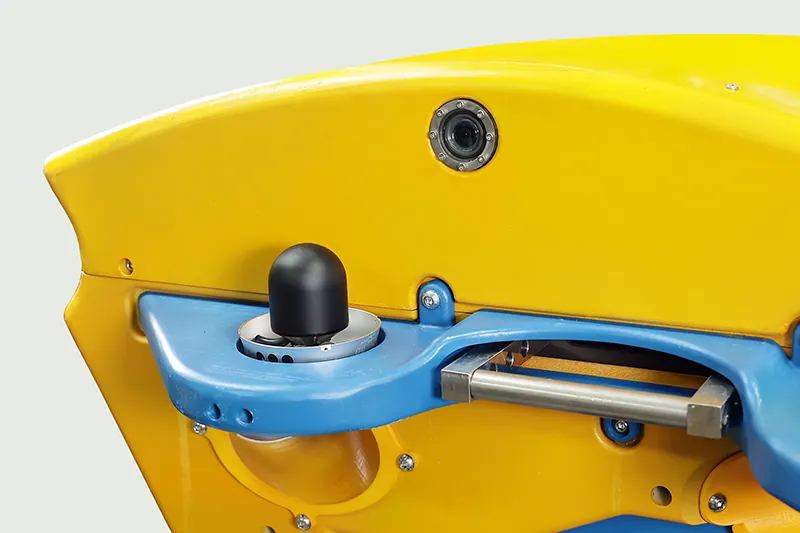
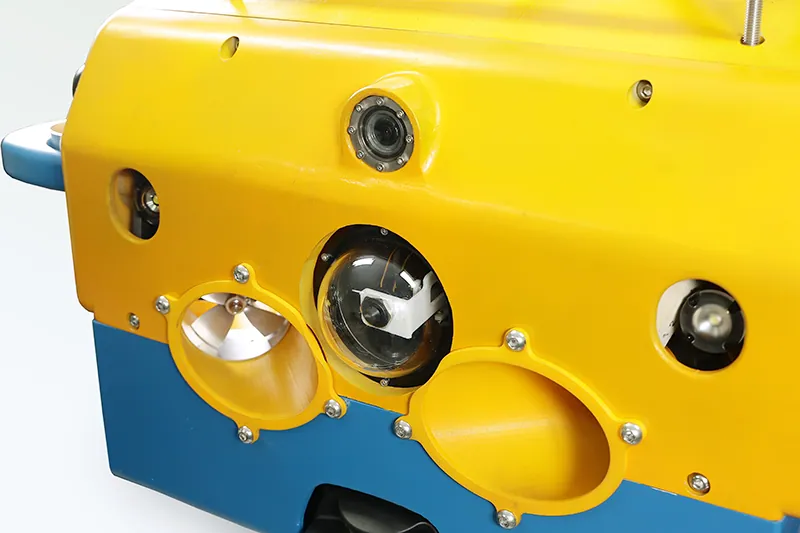
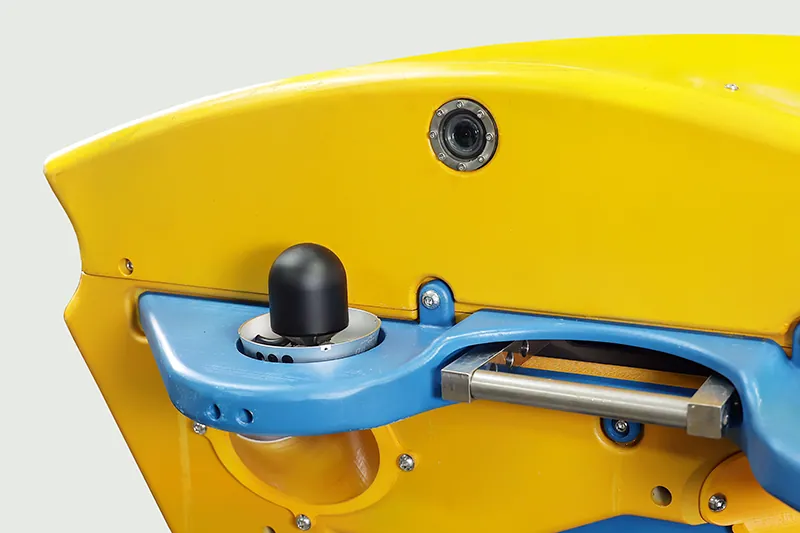
03 Backup Camera
- Cameras to observe the forward view and the arms’ movements
- Surround view cameras to ensure operational safety
- Front-facing LEDs for low-light conditions
Specification
| Diameter | Lifting capacity of robotic arms (in air) | Weight in Air | Maximum speed | Thrust |
|---|---|---|---|---|
| 890 x 840 x 700(h) | 3 kg (average), 6 kg (maximum) | 90kg | 1.5Knot | 5.0kgf |
Case of Use